⚡ Arduino simplifies ROS 2 integration for I/O
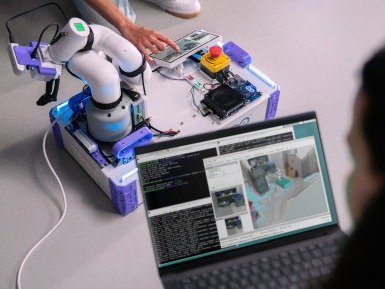
Arduino has unveiled a new method to connect Arduino hardware I/O directly into ROS 2, as presented at ROSCon. This development addresses the common architectural split in robotics where a Linux-based computer handles high-level tasks like navigation and mapping, while a microcontroller manages real-time operations such as GPIO toggling and motor driving. The announcement highlights the difficulty developers traditionally face when bridging these two distinct computing worlds. By streamlining this interface, the solution aims to reduce the complexity of integrating deterministic microcontroller functions with the ROS 2 ecosystem. The update focuses on making the communication between the high-level planning software and the low-level hardware control more accessible for robotics engineers. This approach seeks to eliminate the typical wrestling match required to establish reliable data exchange between the main processor and the peripheral controller. The initiative reflects a broader effort to simplify the development workflow for robotic systems relying on mixed-architecture designs. No specific pricing or immediate availability details were provided in the initial announcement. The focus remains on the technical integration pathway rather than commercial distribution specifics at this stage.